Godot Version
v4.7.2.stable.steam [ed1daf0bf]
Question
How i can fix this issue where two bodies connected via joint still can move apart or close to each other and do not keep they original position
Full map of my joint system
-Node3D
--SteerFrontLeft_Joint [ Car_RigidBody-> SteerPartFrontLeft_RigidBody ]
--SteerFrontRIght_Joint [ Car_RigidBody -> SteerPartFrontRight_RigidBody ]
--RearLeft_Joint [ Car_RigidBody -> WheelRearLeft_RigidBody ]
--RearRight_Joint [ Car_RigidBody -> WheelRearRight_RigidBody ]
--FrontRight_Joint [ SteerPartFrontRight_RigidBody -> WheelFrontRight_RigidBody ]
--FrontLeft_Joint [ SteerPartFrontLeft_RigidBody -> WheelFrontLeft_RigidBody ]
--NoCollideFrontLeft_Joint [ WheelFrontLeft_RigidBody -> Car_RigidBody ]
--NoCollideFrontRight_Joint [ WheelFrontRight_RigidBody -> Car_RigidBody ]
--Car_RigidBody
--WheelRearLeft_RigidBody
--WheelRearRight_RigidBody
--WheelFrontLeft_RigidBody
--WheelFrontRight_RigidBody
--SteerPartFrontLeft_RigidBody
--SteerPartFrontRight_RigidBody
NoCollision joints disable all limits (angular and linear) and just to disable collision between two bodies
SteerJoints have disabled Y axis angular limit and enabled angular Y axis spring and their equilibrium_point is 33 degrees
WheelJoints have disabled Y linear limits, X limits (front wheels have enabled motors on X axis) and enabled Y axis spring
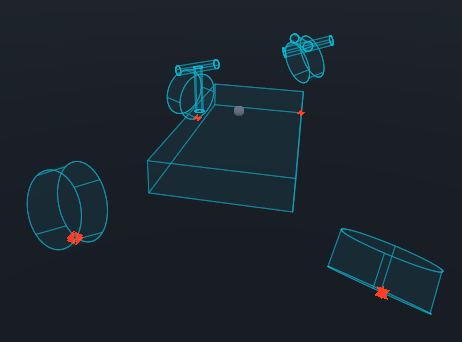
Bodies after some time
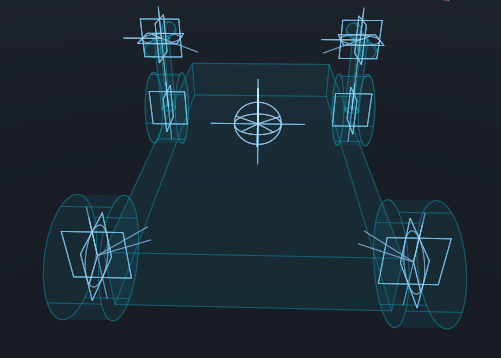
Original shape of car
I know i can build a car using car using VehicleBody3D and VehicleWheel3D but i want to make some physics toys but this sloppy joints are really frustrating.